All courses
Robotics path · course 23 of 143
Robotic Grippers & End-of-Arm Tooling
Intermediate · 5 lessons · 0 complete
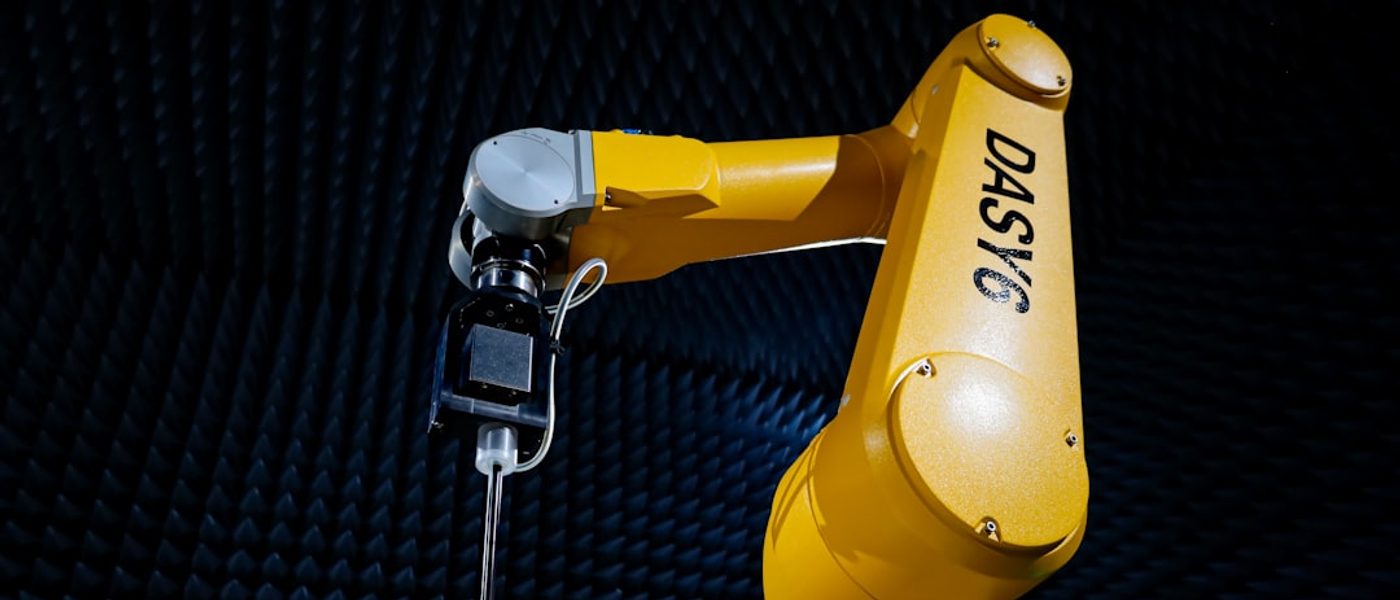
A grasp plan is only as good as the hardware that executes it. This course sets aside grasp planning entirely and goes deep on the physical design of grippers themselves: the major mechanism families, why delicate and irregular objects demand more than a well-tuned force setting, how force and tactile sensing at the point of contact close a feedback loop that vision alone cannot, how industrial arms swap tools automatically to serve multiple jobs in a shift, and why gripper selection is fundamentally a matching problem between hardware and task rather than a search for one best design.