All courses
Robotics path · course 31 of 143
Underactuated Robotics
Advanced · 6 lessons · 0 complete
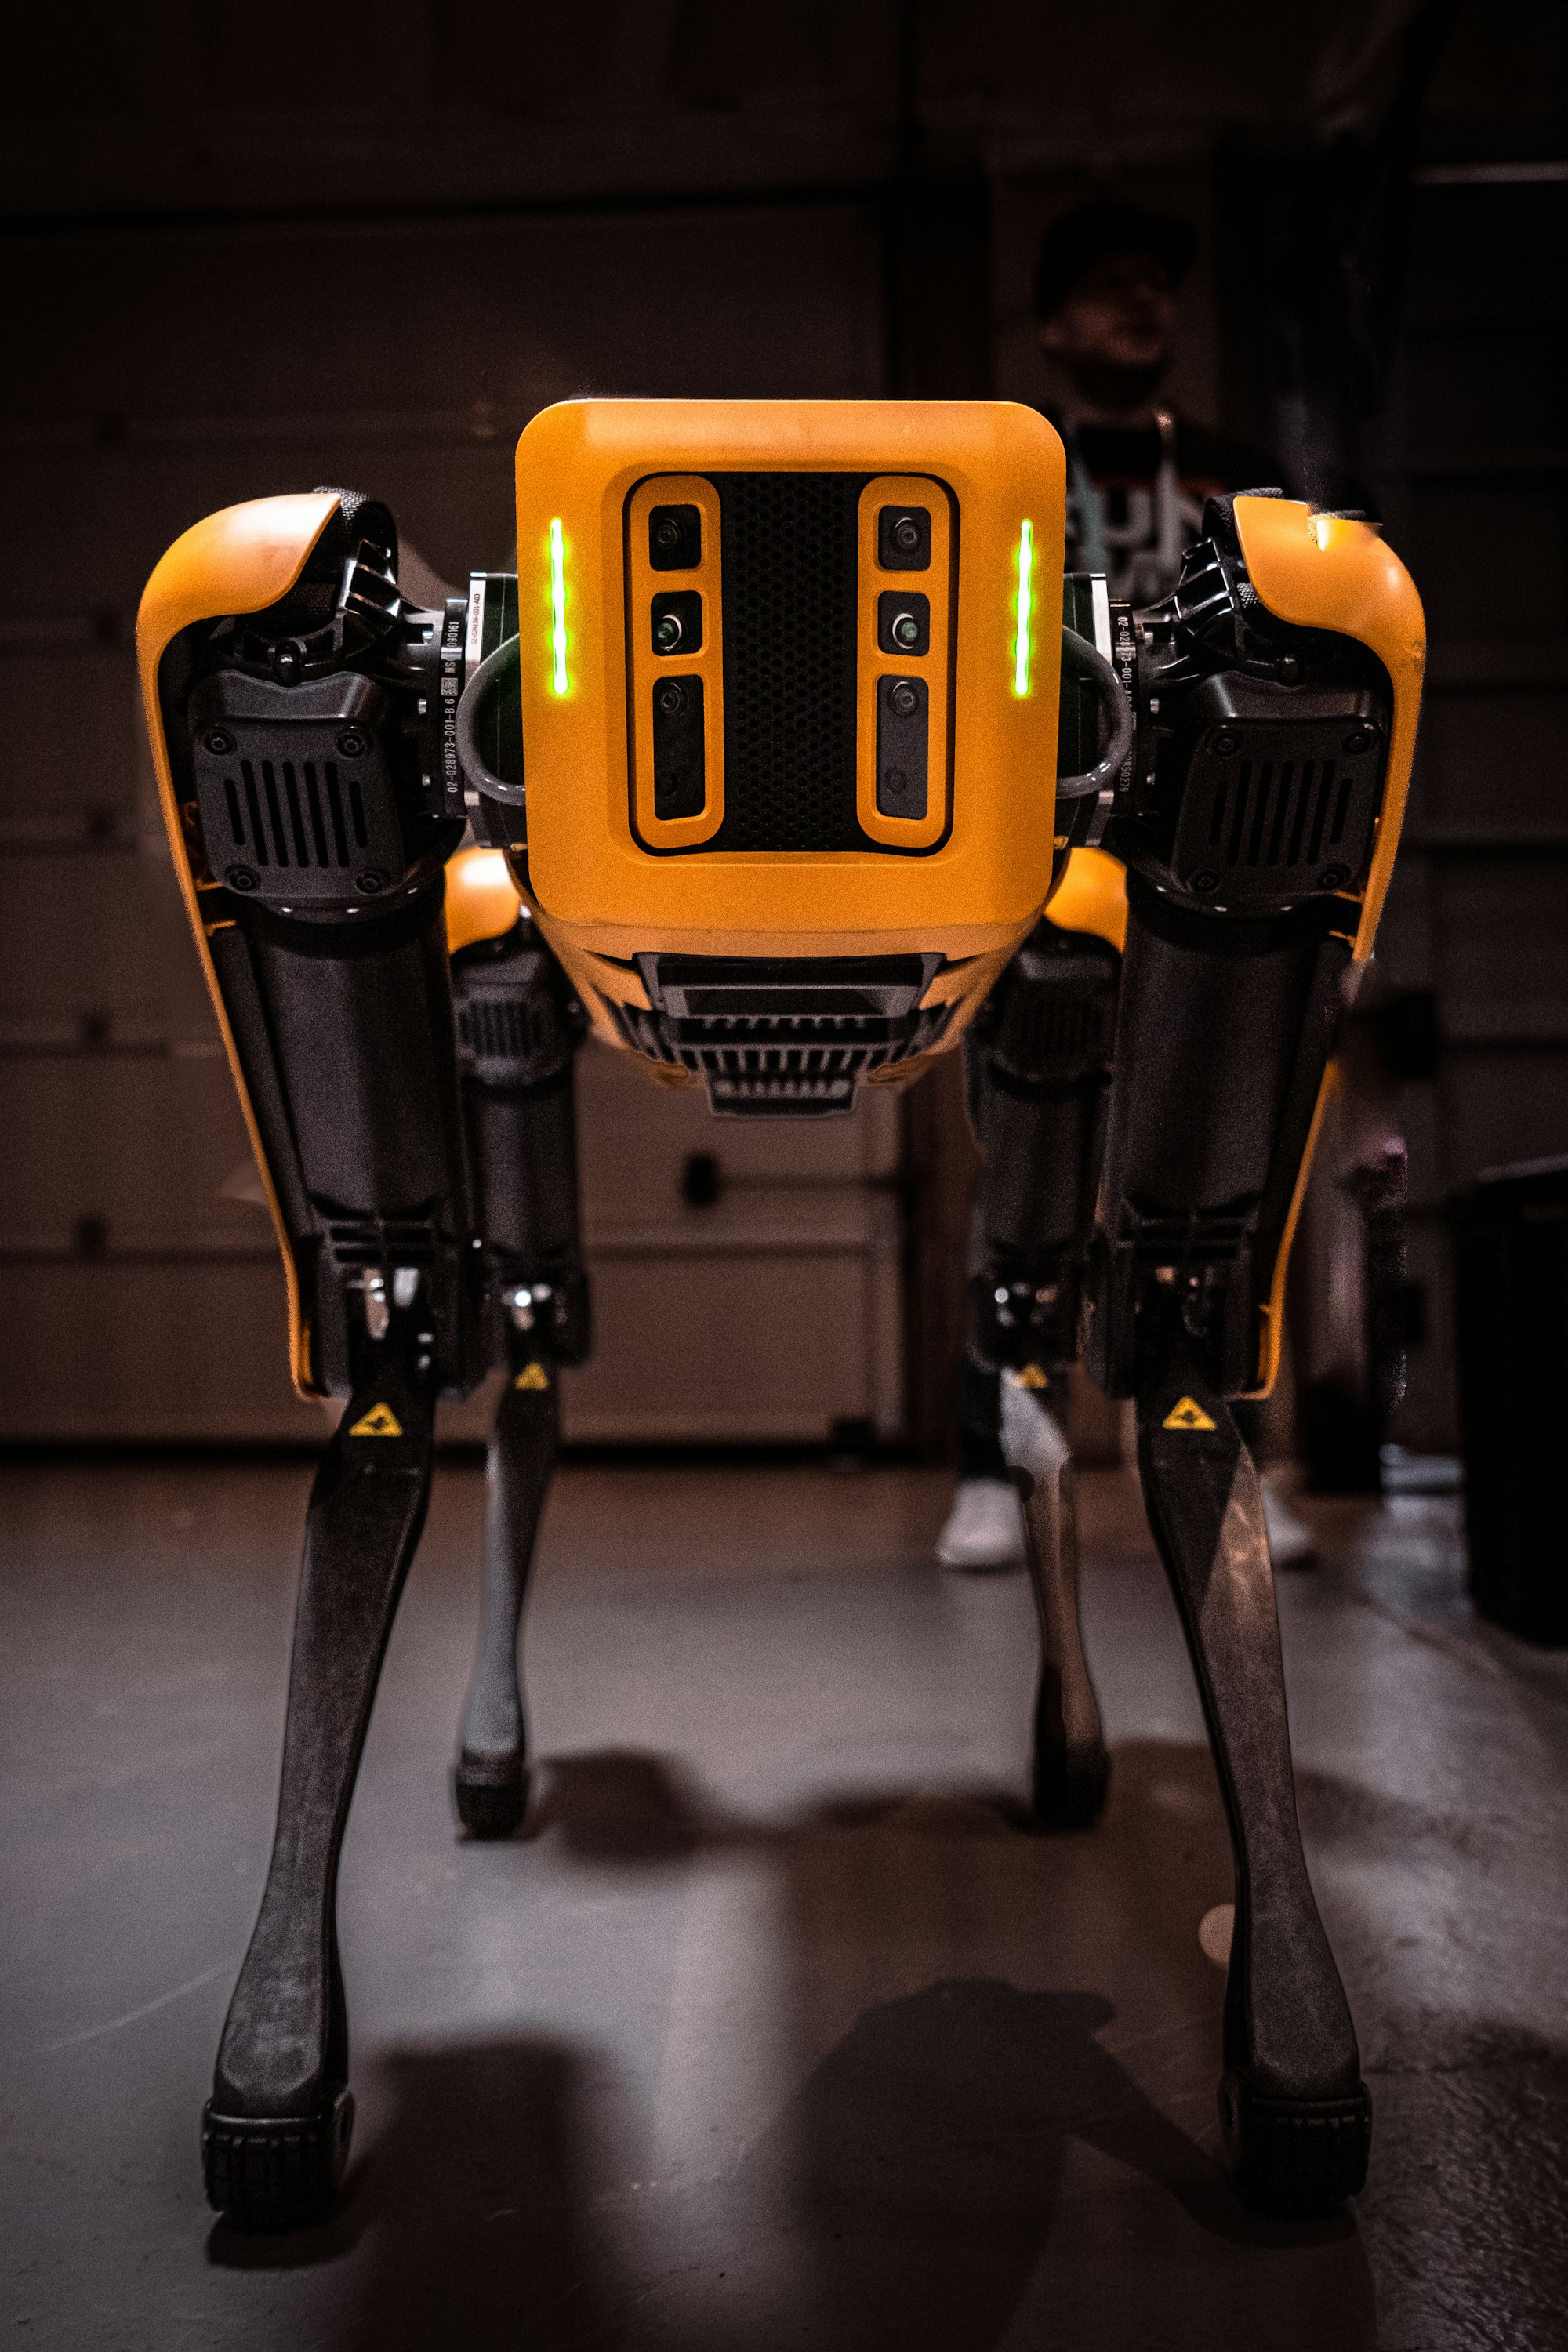
Most real robots don't have a motor for every joint. This course looks at what that means: how to swing a pendulum up with no direct push at its pivot, why some robots walk best by exploiting gravity instead of fighting it, and how trajectory optimization finds motions that a fully-actuated design would never need.